Pentapod— 16:9 Presentation Slides & PPTX Generator
Select Slide to Preview on Canvas (or Export 1:1 Presentation Deck to PPTX):
Pentapod
Zurich, Switzerland
Innovative Brick Module & Robotic Assembly
@Gramazio Kohler Research, ETH Zurich
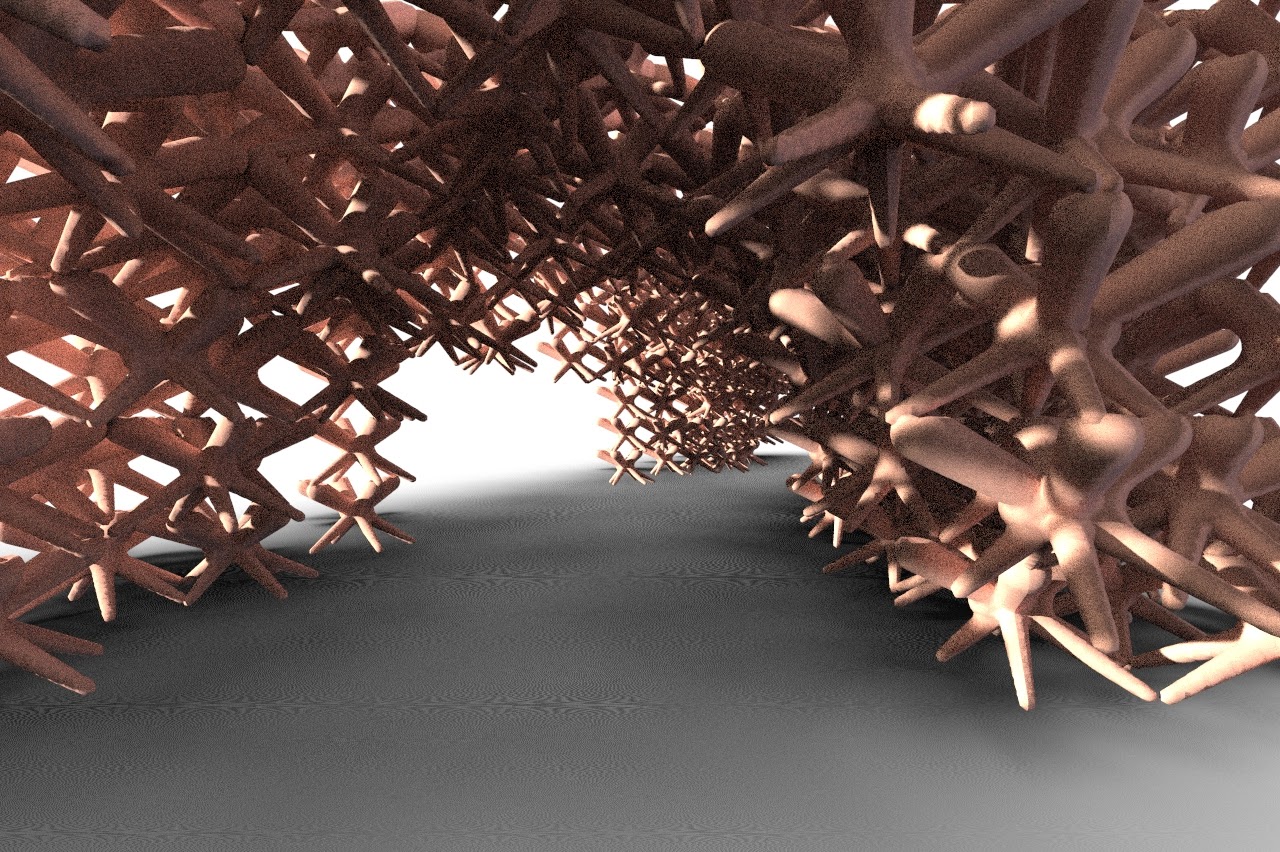
Developed at Gramazio Kohler Research (ETH Zurich), Pentapod investigates novel geometric typologies for robotic masonry construction. By moving beyond conventional rectilinear bricks, the project introduces a five-fold interlocking module engineered for automated robotic pick-and-place workflows. The geometry of the Pentapod module enables multi-directional interlocking connections without relying on wet mortar joints during initial placement. Each unit self-aligns through parametric contact facets, allowing robots to construct structurally stable, double-curved, and porous architectural assemblies. The research combines computational morphology, digital fabrication simulations, and robotic end-effector toolpath optimization to expand the formal and structural envelope of automated brick architecture.
- Robotic Construction
- Digital Fabrication
- Modular Masonry
- Gramazio Kohler Research